
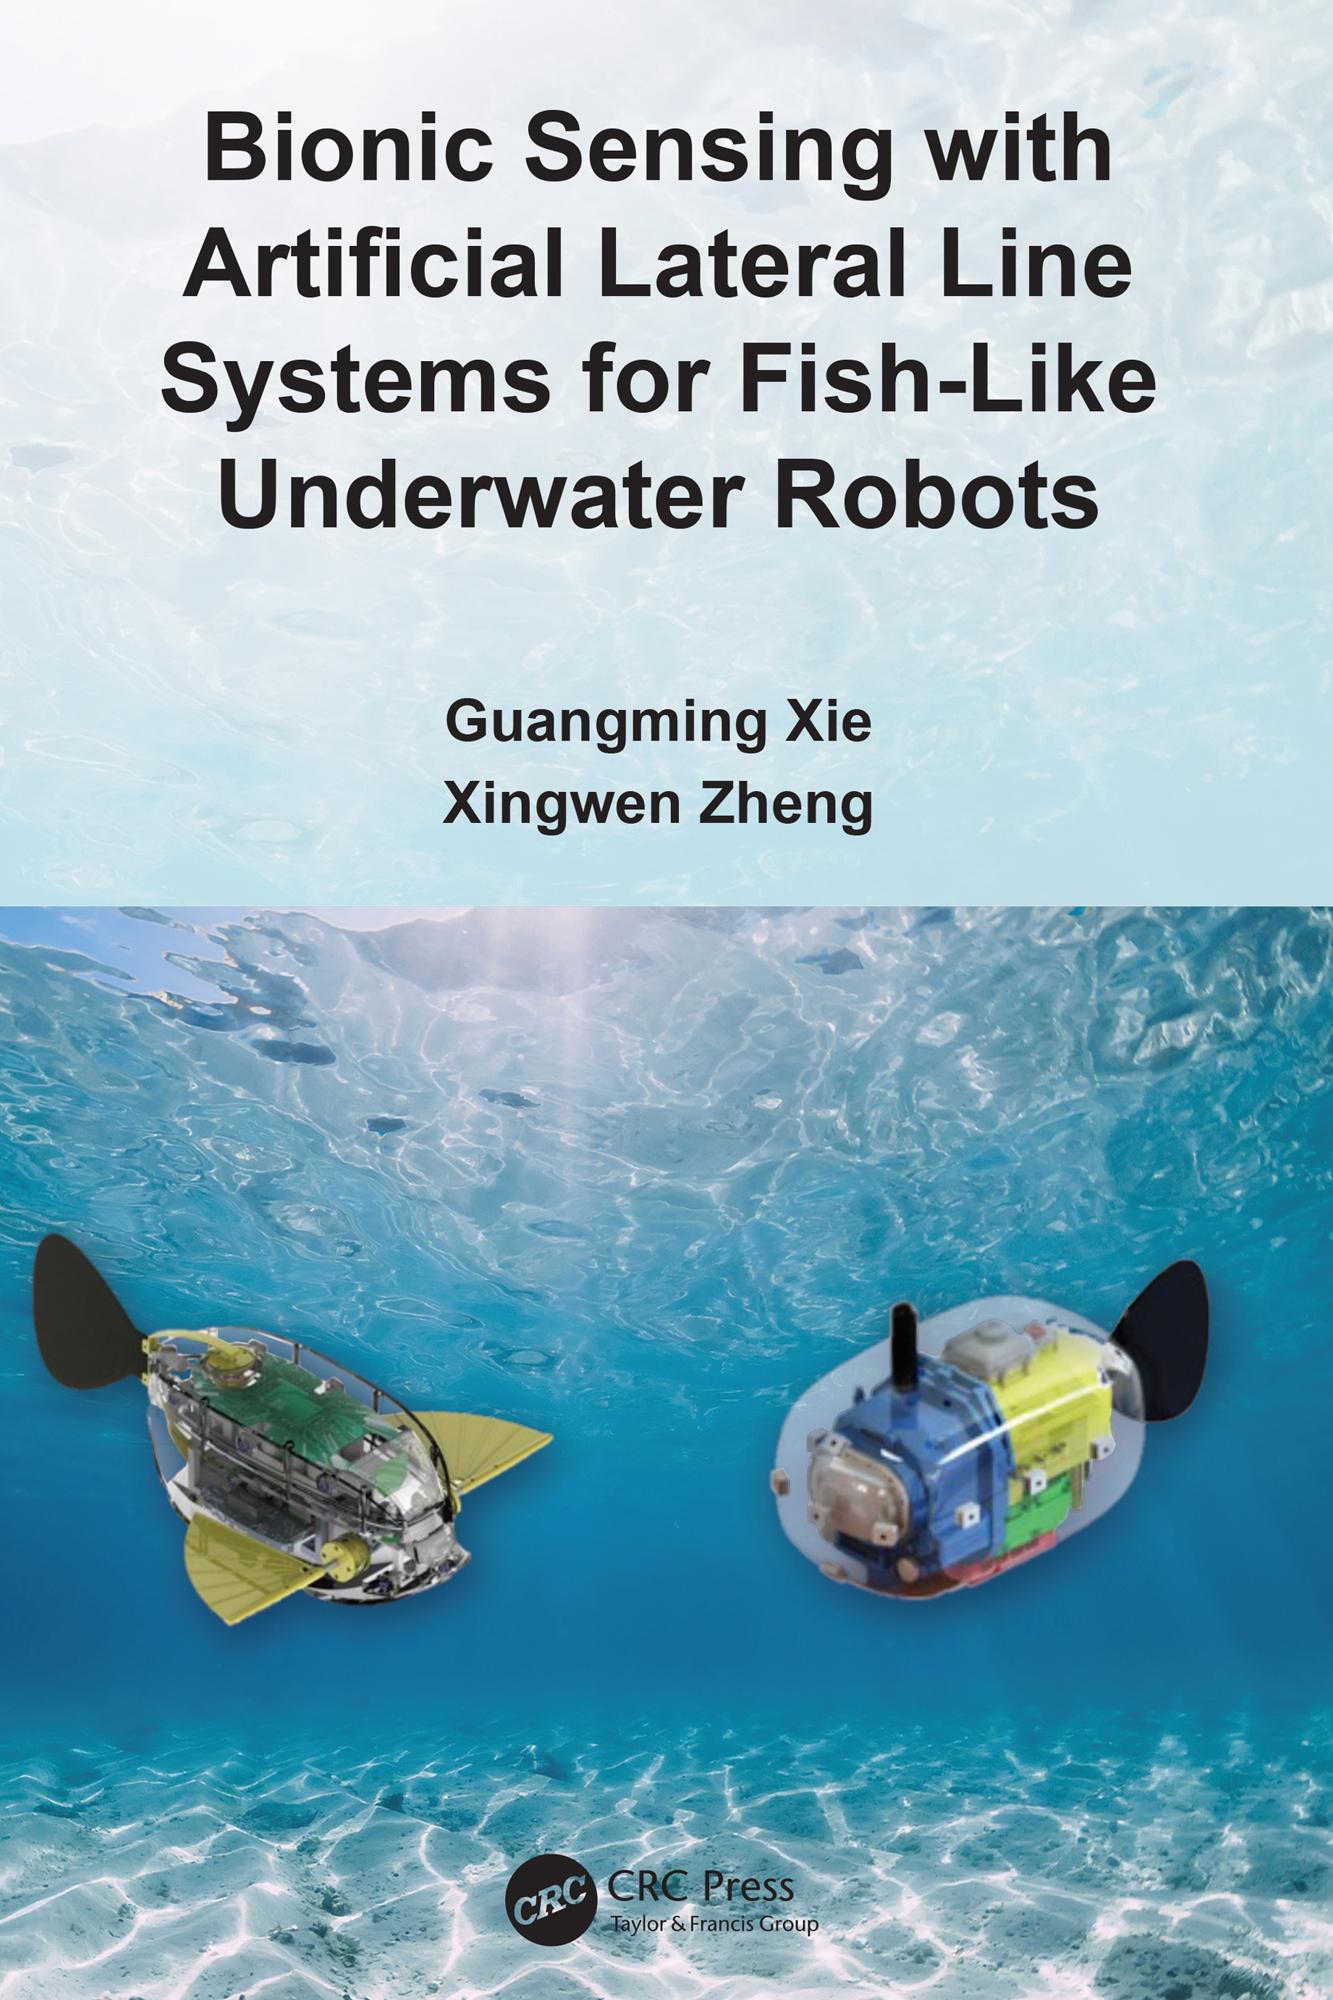
In this book, the authors first introduce two fish-like underwater robots, including a multiple fins-actuated robotic fish and a caudal fin-actuated robotic fish with a barycenter regulating mechanism. They study how a robotic fish uses its onboard pressure sensor arrays based-ALLS to estimate its trajectory in multiple locomotions, including rectilinear motion, turning motion, ascending motion, and spiral motion. In addition, they also explore the ALLS-based relative position and attitude perception between two robotic fish in a leader-follower formation. Four regression methods—multiple linear regression methods, support vector regressions, back propagation neural networks, and random forest methods—are used to evaluate the relative positions or attitudes using the ALLS data.
The research on ALLS-based local sensing between two adjacent fish robots extends current research from one individual underwater robot to two robots in formation, and will attract increasing attention from scholars of robotics, underwater technology, biomechanics and systems, and control engineering.
Payez facilement par carte, Klarna, Apple Pay ou Google Pay. Pas satisfait ? Vous avez toujours une garantie de remboursement de 14 jours. En savoir plus dans nos conditions. Si vous avez des questions, envoyez-nous un e-mail à hello@memmo.org.
Memmo facilite tes études, où que tu sois dans le monde. On rassemble tes manuels de cours et des outils d'étude intelligents au même endroit : résumés, quiz, podcasts et flashcards. Et il y a Ted, ton compagnon d'étude qui répond à toutes tes questions. Plus de 50 000 étudiants étudient déjà ici – conçu pour t'aider à apprendre plus vite et à moins stresser.