
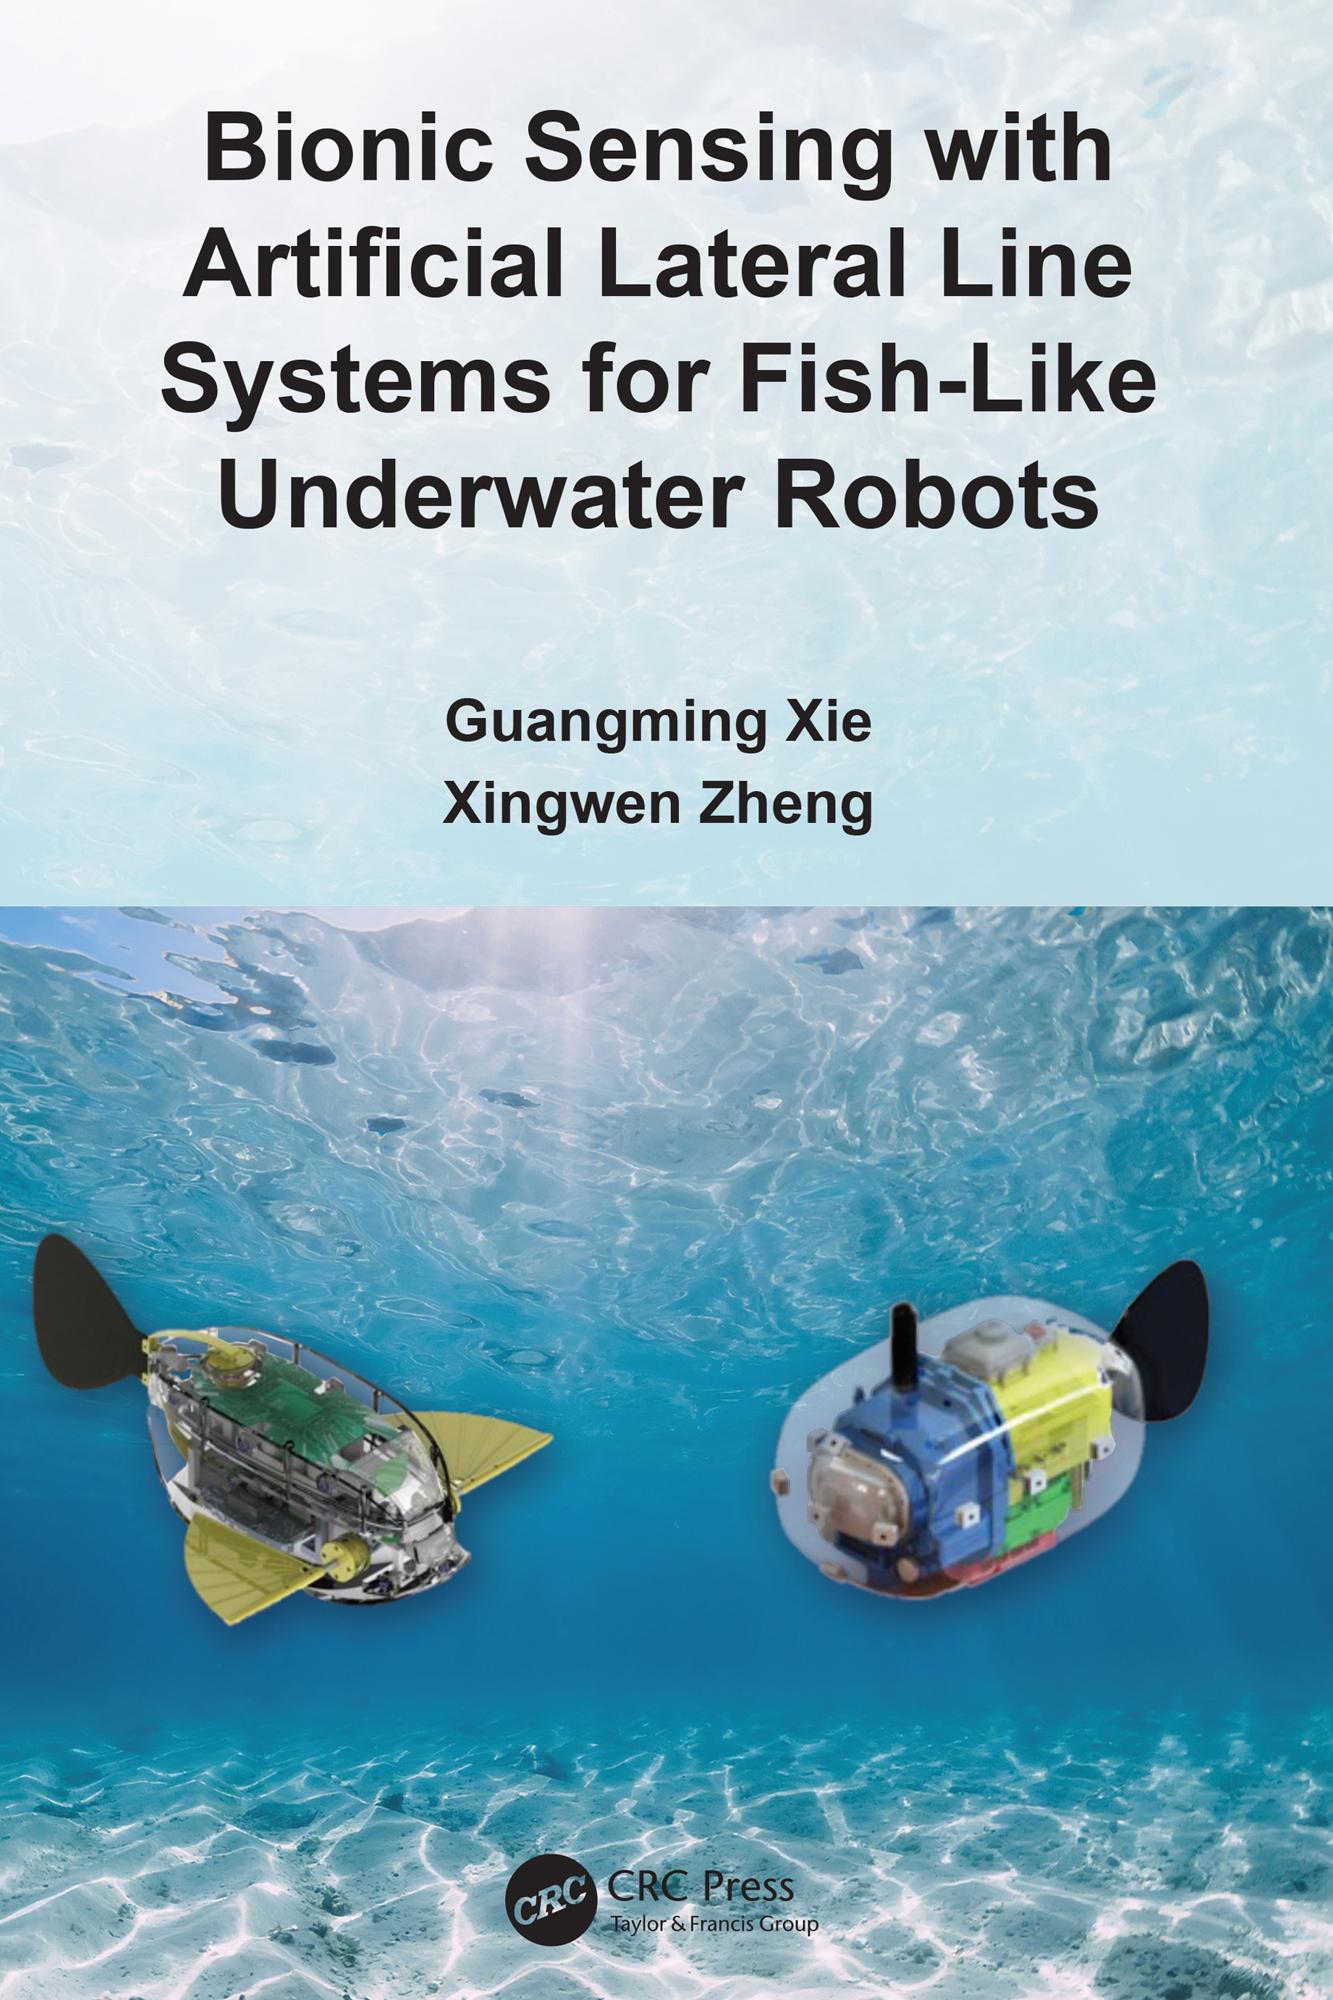
In this book, the authors first introduce two fish-like underwater robots, including a multiple fins-actuated robotic fish and a caudal fin-actuated robotic fish with a barycenter regulating mechanism. They study how a robotic fish uses its onboard pressure sensor arrays based-ALLS to estimate its trajectory in multiple locomotions, including rectilinear motion, turning motion, ascending motion, and spiral motion. In addition, they also explore the ALLS-based relative position and attitude perception between two robotic fish in a leader-follower formation. Four regression methods—multiple linear regression methods, support vector regressions, back propagation neural networks, and random forest methods—are used to evaluate the relative positions or attitudes using the ALLS data.
The research on ALLS-based local sensing between two adjacent fish robots extends current research from one individual underwater robot to two robots in formation, and will attract increasing attention from scholars of robotics, underwater technology, biomechanics and systems, and control engineering.
Paga fácilmente con tarjeta, Klarna, Apple Pay o Google Pay. ¿No estás contento? Siempre tienes 14 días de garantía de devolución. Lee más en nuestros términos. Si tienes preguntas, escríbenos a hello@memmo.org.
Memmo hace que estudiar sea más fácil, estés donde estés. Aquí tienes tus libros de texto y herramientas de estudio inteligentes en un solo lugar: resúmenes, quizzes, podcasts y flashcards. Y también a Ted, tu compañero de estudio que responde a todo lo que te preguntes. Más de 50 000 estudiantes ya estudian aquí. Está hecho para que aprendas más rápido y te estreses menos.