
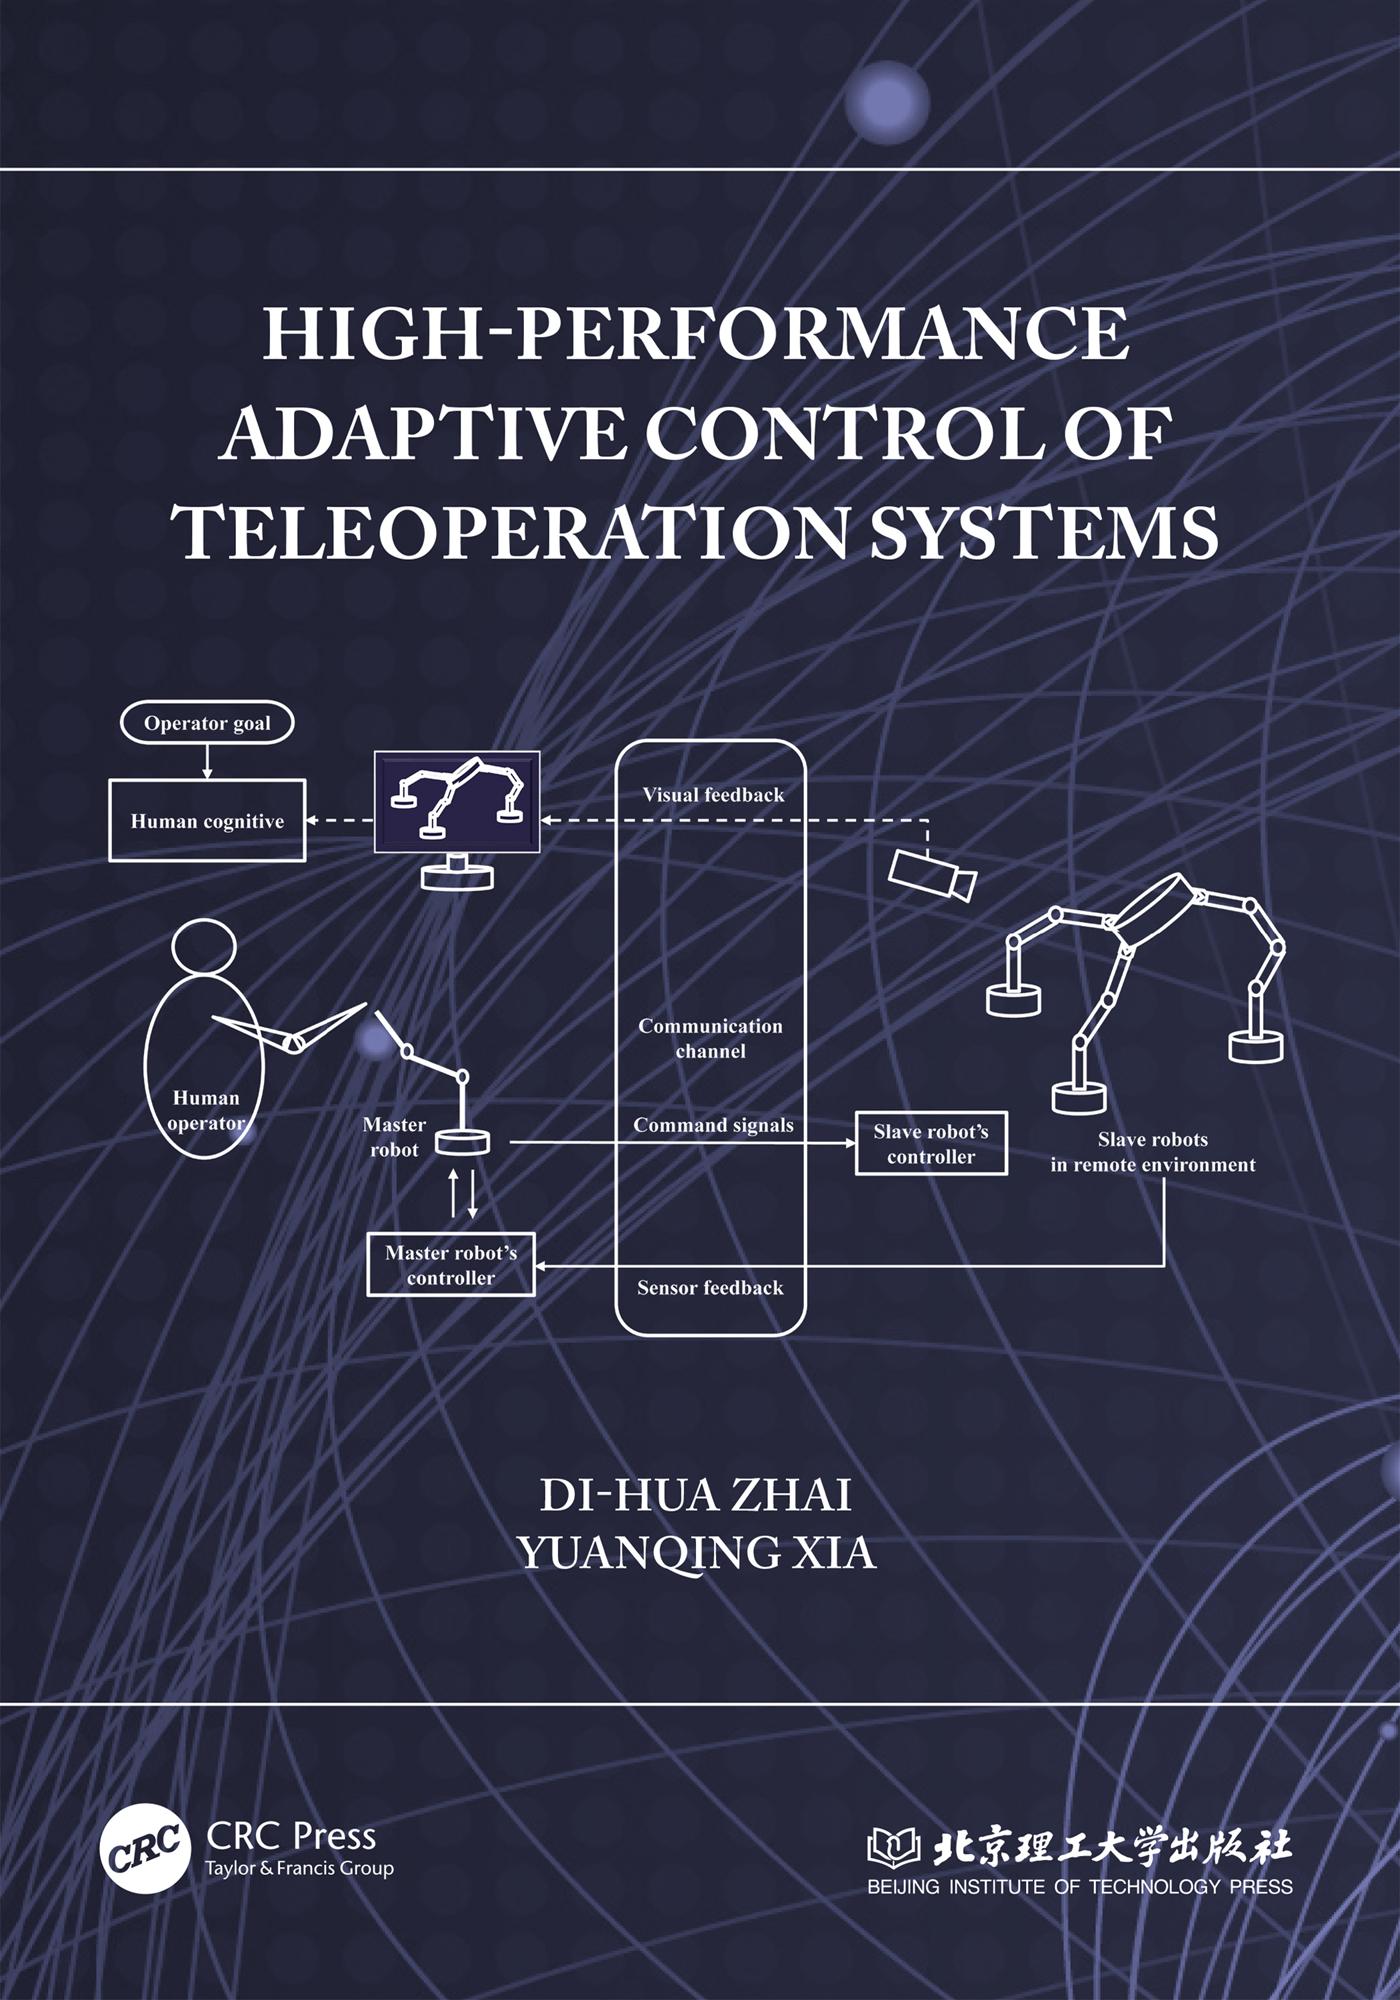
Within a unified switched-control framework, this book investigates the high-performance control designs and theoretic analyses for teleoperation systems, including the joint space and task space teleoperations, the homogeneous and heterogeneous teleoperations, and the single-master single-slave and multi-master multi-slave teleoperations.
The book begins with an introduction to the concepts and challenges of networked teleoperation systems. Then, it investigates a new adaptive control framework based on auxiliary switched filters for the bilateral teleoperation systems to handle the model uncertainty and non-passive external forces. To overcome the input constraints of robotic systems, this adaptive method is also extended to the anti-windup adaptive control case. Furthermore, to apply to multi-robot remote collaboration scenarios and heterogeneous teleoperations, two tele-coordination methods and an adaptive semi-autonomous control method are respectively developed. Finally, the authors examine two finite-time control schemes and two types of improved prescribed performance controls for teleoperation systems to improve the transient-state and steady-state synchronization performances.
This title will be an essential reference for researchers and engineers interested in teleoperation, robotic systems, and nonlinear control systems. It would also prove useful to graduate students in the fields of science, engineering, and computer science.
Zahle einfach mit Karte, Klarna, Apple Pay oder Google Pay. Nicht zufrieden? Du hast immer ein 14-tägiges Widerrufsrecht. Lies mehr in unseren AGB. Hast du Fragen, schreib uns eine E-Mail an hello@memmo.org.
Memmo macht das Lernen einfacher – wo auch immer du bist. Bei uns findest du deine Kursbücher und smarte Lerntools an einem Ort: Zusammenfassungen, Quizzes, Podcasts und Lernkarten. Und Ted, dein Lernbuddy, beantwortet alles, was du wissen möchtest. Über 50.000 Studierende lernen bereits hier – gemacht, damit du schneller lernst und weniger Stress hast.